TACEX
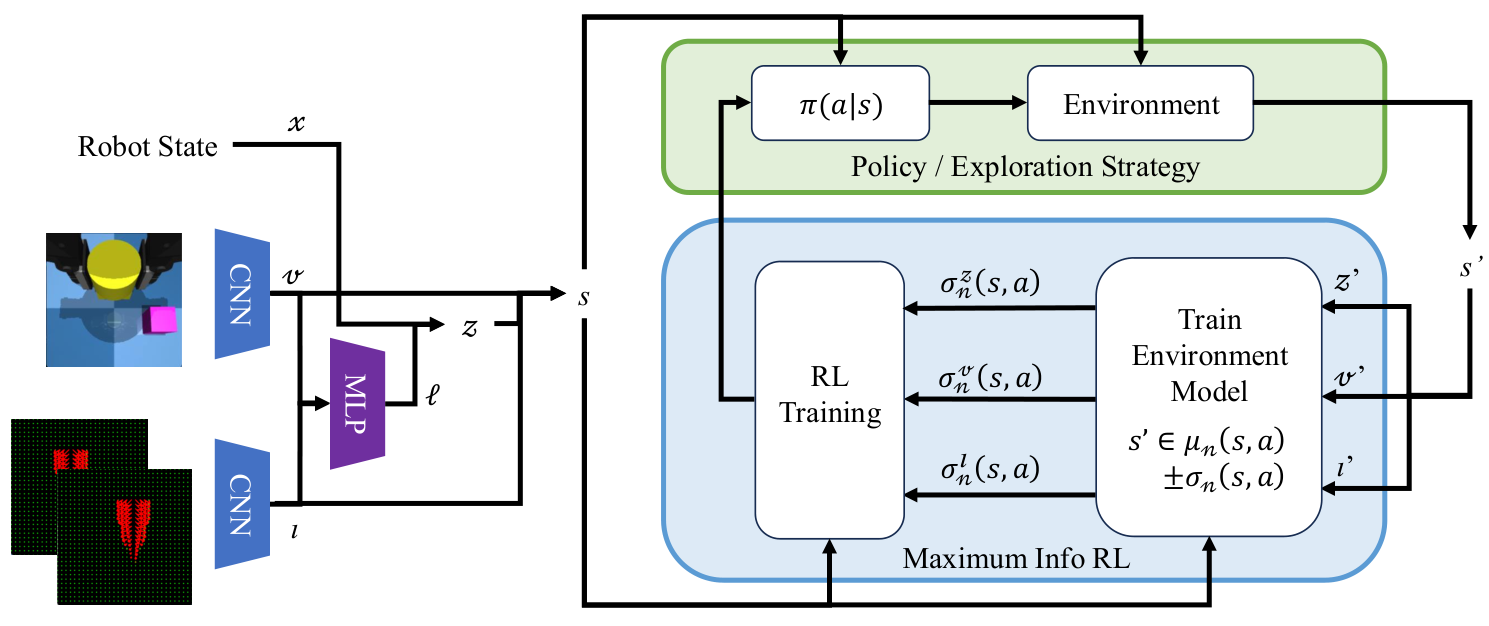
Tactile curiosity guides robots toward contact-rich exploration and efficient manipulation learning.
A selection of my projects. Work in progress.
Tactile curiosity guides robots toward contact-rich exploration and efficient manipulation learning.

Uncertainty-aware continuous-time model-based RL with optimistic planning.

Soft active exploration for soft-robot control; data-efficient exploration.
